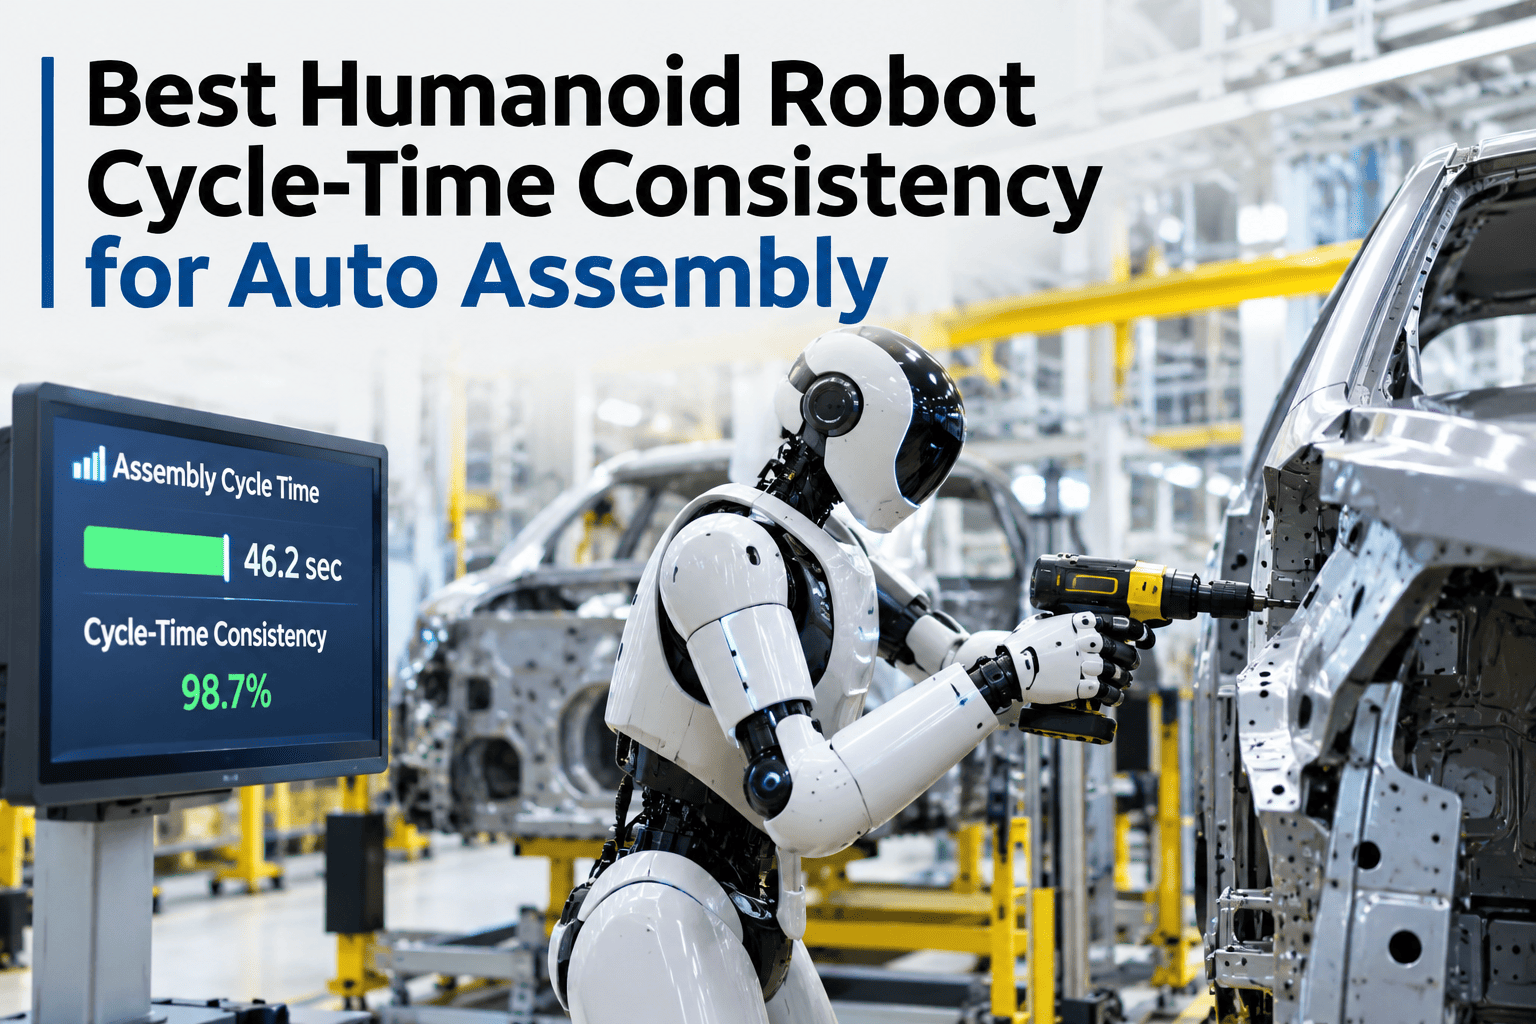
Best Humanoid Robot Cycle-Time Consistency for Auto Assembly

By James Smith on November 21, 2026

best-humanoid-robot-cycle-time-consistency-for-auto-assembly

A humanoid robot cell that averages the correct takt time over a shift can still be hiding a problem, because an average built from some cycles running fast and others running slow masks exactly the kind of variability that creates downstream buffer starvation and blocking on the rest of the line. Measuring takt-time compliance cycle by cycle, decomposing where the variability actually comes from, and planning slack around it deliberately is what keeps a humanoid cell a help to the line rather than a hidden source of instability. iFactory AI, an on-premise AI platform for manufacturing, measures this cycle-by-cycle consistency directly from a cell's own data, and integration teams can see their own humanoid cell's cycle-time variability decomposed with our team.

Humanoid Cycle-Time Consistency, 2027

An Average Takt Time Can Hide a Real Problem

Humanoid robot cycle-time consistency for auto assembly measures takt-time compliance cycle by cycle, decomposes where variability actually comes from, and plans slack to absorb it.

Why the average lies

Why a Good Average Takt Time Isn't the Whole Story

A humanoid cell averaging exactly its target takt time over a shift sounds like a solved problem, but that average can be built from a mix of cycles finishing early and cycles running late by just as much, which looks fine on a summary chart while quietly starving or blocking the stations around it depending on which direction the variability swings on any given cycle. The station downstream doesn't experience the average, it experiences each individual cycle as it actually happens.

Where variability comes from

Decomposing the Sources of Cycle-Time Variation

Grasp and placement
Variation in how quickly the robot locates and secures a part.
Path planning
Variation in the time taken to compute and execute a safe motion path.
Part variability
Variation introduced by inconsistent incoming part position or orientation.
Human interaction
Variation from a shared workspace where a human's pace affects the robot's timing.
A composite scenario

The Cell That Looked Fine on Average and Still Caused Jams

Picture a humanoid cell installed on a trim line, reporting an average cycle time right on target across every shift report for its first month. Despite that, the station immediately downstream kept experiencing intermittent blocking that nobody could explain from the summary data. Once cycle-by-cycle logging was turned on, the pattern became obvious: roughly one cycle in six ran noticeably longer than the rest, driven by a part-grasp retry whenever an incoming bracket arrived slightly rotated from its expected orientation, and those occasional long cycles were exactly what kept backing up the downstream station, even though the shift average absorbed them without showing any problem at all.

The fix, once identified, was narrow: a small adjustment to the incoming part presentation fixture, not a change to the robot's programming at all. Finding that fix required looking at individual cycles, something the average was actively hiding rather than revealing.

From measurement to plan

How Decomposed Variability Leads to a Slack Plan

1
Measure every cycle
Each cycle's actual time is logged, not just the shift average.
2
Decompose the variance
Variation is attributed to grasp, path planning, part or human interaction.
3
Rank the sources
The largest contributor to variability is identified for targeted improvement.
4
Plan the slack
Buffer sizing accounts for the remaining variability rather than assuming a perfect average.

See Your Cell's Variability Sources Ranked

Share a shift of cycle data from your humanoid cell, and iFactory AI will show how the variability breaks down.

Average vs cycle-by-cycle

Two Ways to Look at the Same Cell

Average takt time only
Looks on target over a full shift
Downstream blocking and starving look unexplained
No way to know which cycles are the problem
Cycle-by-cycle measurement
Shows exactly which cycles run long or short
Downstream blocking and starving are explained directly
The specific variability source can be targeted
Planning slack deliberately

Why Slack Should Be Designed, Not Left to Chance

Once the real sources of variability are known, buffer and slack planning becomes a deliberate engineering decision rather than a reactive patch applied after a line keeps jamming unexpectedly. A cell whose variability mostly comes from part positioning calls for a different slack strategy than one whose variability comes from a shared human workspace, and sizing the buffer around the actual dominant source, rather than a generic rule of thumb, avoids both under-protecting the line and over-building buffer that ties up floor space for no benefit.

Common mistakes

Mistakes That Undercut Cycle-Time Consistency Work

1
Judging a cell on shift average alone
The average can look fine while the line still experiences real instability.
2
Treating every source of variability the same
A grasp issue and a part-supply issue need completely different fixes.
3
Sizing buffers by guesswork
A buffer not sized to the actual variability either starves the line or wastes floor space.
Expert review

What an Industrial Engineer Would Check First

The shift average is the least useful number on the dashboard. Confirm cycle-by-cycle data is being captured and decomposed before trusting any claim about a humanoid cell's real consistency.
Watch for
Downstream blocking or starving with no cycle-level data to explain its cause.
Do next
Start by logging raw cycle times for one shift before changing anything about the cell.
FAQ

What Integration Teams Ask About Cycle-Time Consistency

How granular does cycle-time data need to be to find real patterns?
Capturing the full duration of every individual cycle, rather than only a shift or hourly average, is what's needed to see the variability a summary number hides. Ask what data your cell already generates.
Can this decomposition work on a cell that's already in production?
Yes, decomposition is usually done on data from an already-running cell, since real production conditions reveal variability sources a pre-launch test environment may not. Ask about analyzing your running cell.
How do we fix variability caused by inconsistent part positioning?
Depending on the specific cause, fixes range from improving upstream part presentation to adjusting the robot's vision or grasp strategy, and the right one depends on which part of the process is actually introducing the inconsistency. Discuss your specific part variability.
Does a shared human-robot workspace always increase variability?
It typically adds some variability since a human's pace isn't perfectly uniform, but the amount depends heavily on how the task is divided, and some divisions of labor minimize the human's influence on the robot's own cycle timing. Ask about your specific cell layout.
How much buffer is actually needed once variability is known?
Buffer sizing is calculated from the measured variability itself rather than a generic rule, so a cell with tightly controlled cycles can run with much less slack than one with wider swings. Ask about sizing your own buffer.
Know what's behind the average

Find Out What's Really Driving Your Cell's Variability

Book a session with iFactory AI to decompose your humanoid cell's cycle-time variability and plan slack deliberately.
Share This Story, Choose Your Platform!