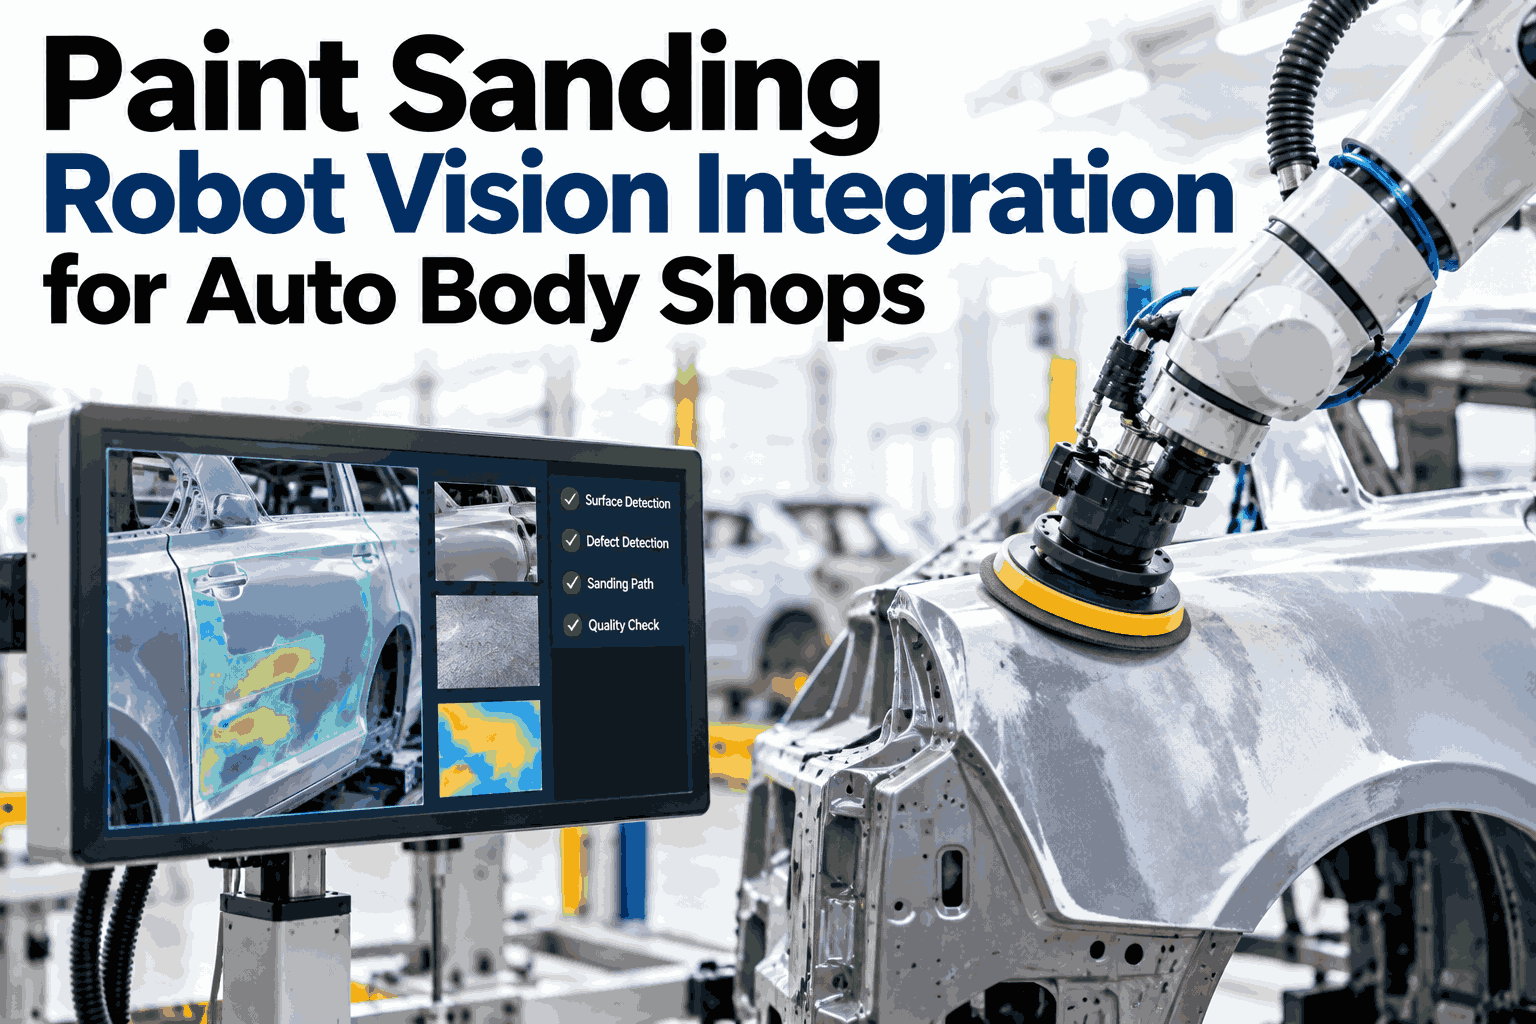
A sanding robot is only as good as the instructions it receives. Hand it a vague target and it will sand the wrong spot or press too hard. Hand it an exact position, the right path and a force ceiling, and it can remove a dirt inclusion without touching the clear coat around it. That precision depends on one link: the connection between the vision system that finds the defect and the robot that fixes it. Repair teams can trace one defect from inspection image to sanded spot on their own cell and see which step adds the most uncertainty.
Let Vision Tell the Robot Exactly Where to Sand
iFactory Automotive Paint AI turns defect findings into robot coordinates, picks the sanding path and keeps force inside a safe range.
Who Does What in a Repair Cell
Automation works best when the split is clear. Machines take the repeatable passes, and people keep the judgment calls.
The goal is not an empty repair area. It is a repair area where skilled people spend time on skilled work.
Where Position Error Comes From
Every stage between camera and abrasive adds a little uncertainty. The sum decides whether the robot hits the defect or misses it.
The Shape of a Controlled Sanding Pass
Force is not a constant. A good pass approaches gently, works inside a window and retracts cleanly.
Measure Your Own Position Error
Bring your cell layout and one defect example. We will outline where error enters and how to tighten it.
Choosing the Approach by Defect
Different defects need different abrasives and motions. The system selects from your approved recipes instead of improvising.
| Defect | Typical Approach | Key Control |
|---|---|---|
| Dirt inclusion | Small orbital pass, fine abrasive | Limit the area worked |
| Crater | Localized sanding, then recheck depth | Stop before burn-through |
| Light run | Linear pass along the streak | Follow the surface angle |
| Orange peel patch | Even overlapping area passes | Uniform pressure |
| Deep damage | Route to technician | Do not attempt automatically |
Built-In Stop Conditions
Autonomous does not mean unattended. These conditions halt the pass and hand control back to a person.
Force exceeds the ceiling
The tool retracts at once and logs the event.
Position looks wrong
If the defect is not where expected, the robot does not guess.
Defect is out of scope
Large or unusual damage is routed to a technician.
Recheck fails
If vision still sees the flaw, the part is flagged, not sanded again blindly.
Closing the Loop With Verification
Every repair ends with a look. Vision confirms the result before the body moves on.
Rolling It Out in Three Phases
Prove the loop on a narrow scope before extending to more panels.
Choose one panel and two defect types. Calibrate the camera and robot frames.
Run with a technician watching and compare results against manual repair.
Add defect types and panels, and use repair logs to find upstream causes.
Frequently Asked Questions
How precise does the positioning need to be?
It must be good enough to land the tool on the defect with margin to spare. The required level depends on defect size and tool footprint. Work out the accuracy your defects demand with our engineers before choosing hardware.
What happens if the panel is slightly misplaced?
Panel location is checked before sanding, using fixtures or vision. If the offset exceeds a limit, the robot does not proceed. Small offsets can be corrected automatically from the measured position.
Can we use our existing robot?
Possibly, if it supports force control and external position input. Many repair cells use robots chosen for that purpose. Check whether your robot model can take vision-based targets in a short review.
How do we stay compliant with robot safety rules?
The cell follows your site's guarding and safety standards, with stop conditions added on top. The AI does not replace formal safety assessment, which remains your responsibility and your safety team's sign-off.
What do repair logs tell us?
They show which defects recur, where on the body and at what time. Patterns point to booth, material or process causes. See how repair history can steer upstream fixes on a short call.
Turn Defect Findings Into Precise Repairs
Bring one repair cell and a few defect examples. We will show the full path from image to coordinates to a verified sanded spot.